OK-Robot: open, modular home robot framework for pick-and-drop anywhere
Hi all, excited to share our latest work, OK-Robot, which is an open and modular framework to perform navigation and manipulation with a robot assistant in practically any homes without having to teach the robot anything new! You can simply unbox the target robot, install OK-Robot, give it a "scan" (think a 60 second iPhone video), and start asking the robot to move arbitrary things from A to B. We already tested it out in 10 home environments in New York city, and one environment each in Pittsburgh and Fremont. We based everything off of the current best machine learning models, and so…
OK-Robot: open, modular home robot framework for pick-and-drop anywhere launched on February 23, 2024 with 542 votes, #41 of 3,962 launches that month and more than 99% of that year's launches. The site was still online in September 2026, 2 years on.
In plain words
OK-Robot is an open-source framework that enables home robots to perform navigation and object manipulation tasks without requiring task-specific training. Users can scan their home environment with a 60-second video, then direct the robot to move items between locations. Built on existing machine learning models, the system has been tested across multiple homes in New York, Pittsburgh, and Fremont. The framework is designed for developers and robotics enthusiasts who want to deploy robots in diverse residential settings.
written from the facts on this page · September 2026
From the sources
OK-Robot is an open framework for a modular system for zero-shot, language conditioned pick-and-drop tasks in arbitrary homes. OK-Robot accomplishes this with a modular design, using 3D VoxelMap for open-vocabulary navigation, AnyGrasp and LangSam for open-vocabulary grasping, and a dropping primitive for placing.
Remarkable progress has been made in recent years in the fields of vision, language, and robotics. We now have vision models capable of recognizing objects based on language queries, navigation systems that can effectively control mobile systems, and grasping models that can handle a wide range of objects. Despite these advancements, general-purpose applications of robotics still lag behind, even though they rely on these fundamental capabilities of recognition, navigation, and grasping. In this paper, we adopt a systems-first approach to develop a new Open Knowledge-based robotics framework called OK-Robot. By combining Vision-Language Models (VLMs) for object detection, navigation…from ok-robot.github.io
In the maker’s words, at launch
Hi all, excited to share our latest work, OK-Robot, which is an open and modular framework to perform navigation and manipulation with a robot assistant in practically any homes without having to teach the robot anything new! You can simply unbox the target robot, install OK-Robot, give it a "scan" (think a 60 second…
Does a similar job
all alternatives → Dobb·E – towards home robots with an open-source platform2023 · dobb-e.com · ▲394
Hi HN! Proud to share our open-source robot platform, Dobb·E, a home robot system that needs just 5 minutes of human teaching to learn new tasks. We've already taken Dobb·E to 10 different homes in New York, taught it 100+ tasks, and we are just getting started! I would love to hear your thoughts about this. Here are some more details, below (or see a Twitter thread with attached media: https://twitter.com/i/status/1729515379892826211 or https://nitter.net/i/status/1729515379892826211): We engineered Dobb·E to maximize efficiency, safety, and…


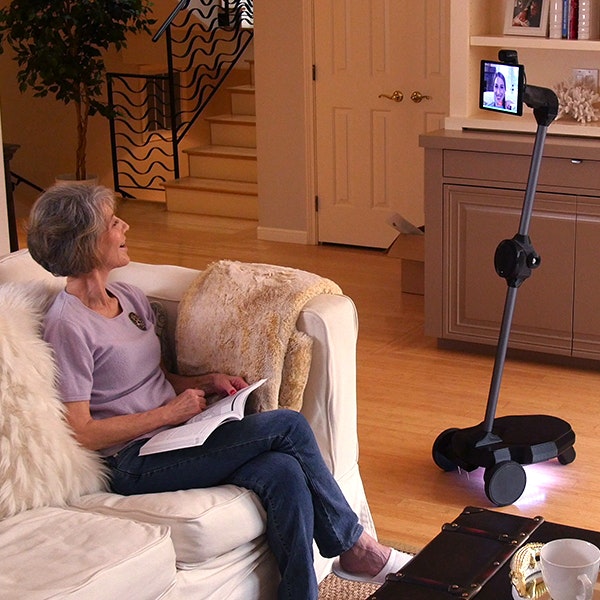 Ohmni by OhmniLabs2017 · indiegogo.com · ▲110
A robot to transform how you communicate with your family
 Robot Utility Models: open-source robots working in new envs zero shot2024 · robotutilitymodels.com · ▲11
Hi all! Sharing our latest work on Robot Utility Models: open source robot models for some useful tasks like door or drawer opening at ~90% success rate that should just work out of the box (given that you have a robot, of course.) Why is this exciting? The state of the art for robot learning thus far has been reliant on pre-training/fine-tuning paradigm: models are first trained on large datasets, then you bring it to your own environment, collect more data, and fine-tune the model on that data. This is not ideal if you want to make robots that work in every home out of the box of…
 Sowbot – Open-hardware agricultural robot (ROS2, RTK GPS)Feb 2026 · sowbot.co.uk · ▲181
Sowbot is an open-hardware agricultural robot designed to close the "prototype gap" that kills most agri-robotics startups and research projects — the 18+ months spent on drivers, networking, safety watchdogs, and UI before you can even start on the thing you actually care about. The hardware is built around a stackable 10×10cm compute module with two ARM Cortex-A55 SBCs — one for ROS 2 navigation/EKF localisation, one dedicated to vision/YOLO inference — connected via a single ethernet cable. Centimetre-level positioning via dual RTK GNSS, CAN bus for field comms, and real-time…
More ai this month
the category →


Paintings by AI models: programs run through a simulation of oil paint.
AI · 21d ago · stillwet.art
 PixVerse R2▲381
A real-time world model you can explore and change
AI · 29d ago · world.pixverse.video

Source: Show HN post ↗ · launch text quoted in part
Launched alongside, February 2024
the whole month →


 MarketingIdeas.com▲1,230
Never run out of marketing ideas ever again
Growth · 2024 · marketingideas.com